Show HN: Artificer by Nua: Frontier robotics task evaluation in 4B parameters
We’re happy to introduce Artificer, our first robotics decision model for evaluating robot task progress and success. The problem Robot systems need feedback during training, evaluation, and deployment. An arm might gra…
以下正文同步自 Hacker News 最新,版权归原站所有,已转换为易读排版。
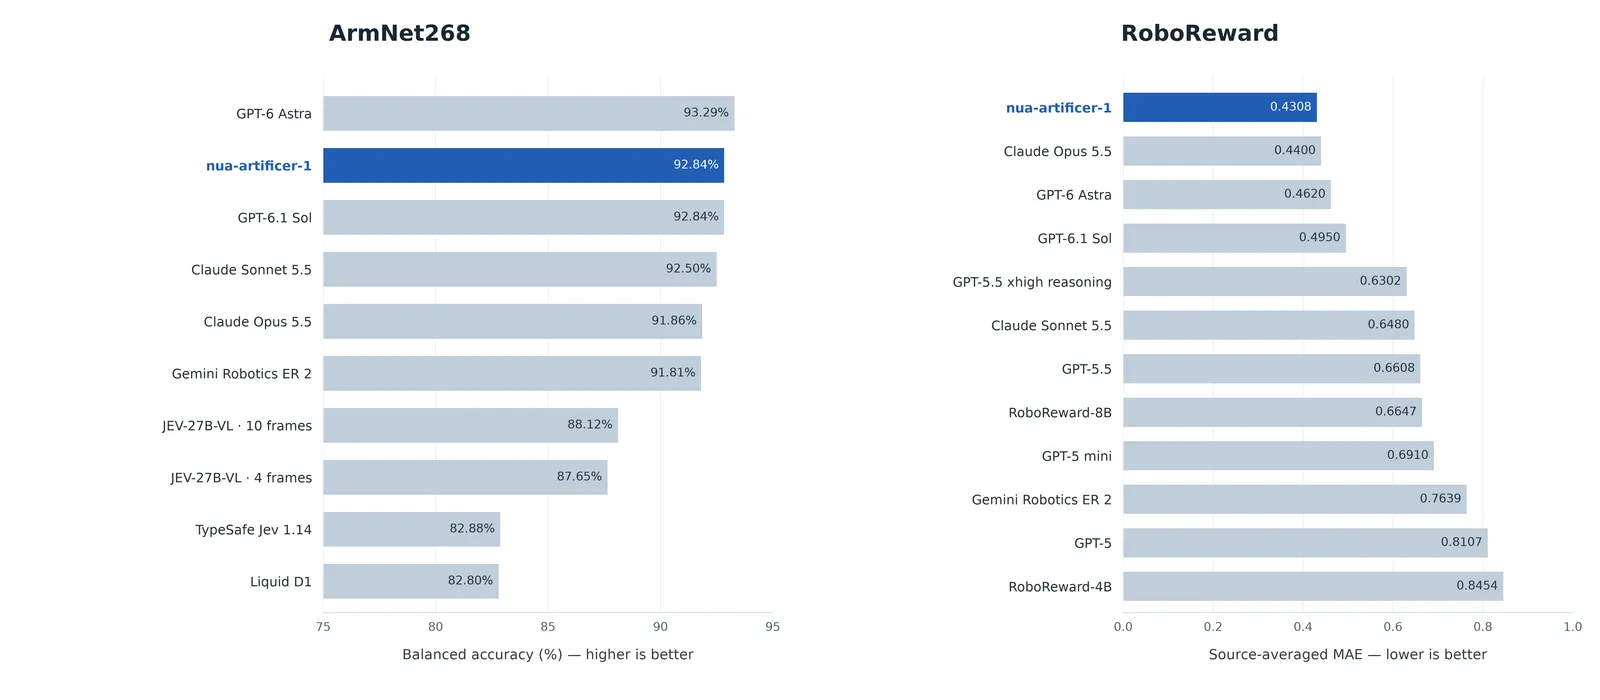
We’re happy to introduce Artificer, our first robotics decision model for evaluating robot task progress and success. The problem Robot systems need feedback during training, evaluation, and deployment. An arm might grasp the right object, but place it in the wrong bin. A robot might’ve only completed part of its task before it stopped. Assessing these outcomes from video often requires manual review or brittle, handcrafted objectives. Though frontier models do well in evaluation, they are expensive and slow. Artificer is a 4B parameter model that estimates task completion and progress, at the frontier level, from a task description and video. During deployment, these estimates provide feedback to a robot controller to help decide whether to continue an attempt, retry, or move to the next task.Know a robotics team working on task evaluation or success detection? We'd appreciate an introduction! For the robotics founders: we’d love to test Artificer on your task videos! Would love to chat more in the comments or over email! sunny@trynua.dev Comments URL: https://news.ycombinator.com/item?id=50296436 Points: 3
Comments: 2
正文由 探How 从来源站点 RSS 同步,内容未经改写;遇到排版缺失或需要图片、视频时请以原文为准。